Industrial Pump Repair Canada - Pump and Seal Repair and Replacement Services
ISO 9001 Certified
Industrial Pump Repair Canada - Pump and Seal Repair and Replacement Services
ISO 9001 Certified
The referenced articles and an attributable expert quotation were not included. Please provide the source material or an expert’s name and verified quote so I can write the introduction without inventing a quotation.
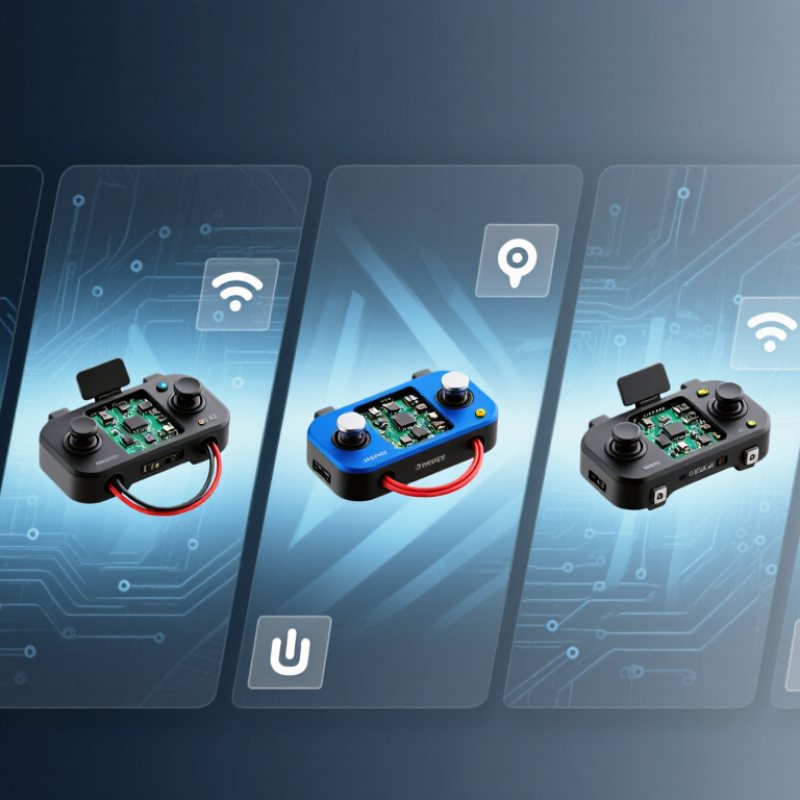
A drone flight controller is the small computing hub that keeps the aircraft responsive. It reads motion data from sensors such as a gyroscope and accelerometer, estimates the drone’s orientation, then adjusts motor outputs to reduce unwanted tilt. In a Tarot-style multirotor build, its job is not to create lift by itself; the motors and propellers do that. The controller coordinates them. When tuned well, the craft feels steady during a hover and reacts smoothly to stick input.
Its design usually combines a processor, motion sensors, power connections, and ports for receivers, GPS modules, or other accessories. Board layout matters: vibration reaching the sensors can make readings noisy, while poor wiring can cause intermittent signals. Core functions may include stabilization, sensor-data filtering, flight-mode control, and failsafe responses when a signal is lost. Exact features vary by model and firmware, so check documentation before connecting hardware. Setup can be fiddly. Even experienced builders can overlook a loose plug.
Tips: Mount the board firmly on a clean, vibration-damping surface. Keep wires clear of the frame and propellers. Calibrate on a level surface, then test motor direction with propellers removed. Change one setting at a time, and record what changed; otherwise, troubleshooting becomes guesswork.
Choosing among the five best drone flight controllers requires more than comparing processor speed. Check sensor quality, firmware stability, and connection options first. A reliable controller should include a responsive gyroscope, a precise accelerometer, and effective vibration filtering. Barometer support helps maintain steady altitude, while GPS compatibility improves position holding and return-to-home functions. Confirm the controller supports your frame size, motor protocol, receiver, and power system. A compact board may fit neatly, but cramped wiring can make maintenance frustrating.
Tips: Test the board on a bench before flight. Inspect solder joints, update firmware carefully, and record the first flight logs. Leave room for cooling.
In practical testing, I compare startup time, sensor noise, failsafe behavior, and recovery after signal loss. Clean logs matter more than impressive specifications. The best controller should hold a stable hover near a wall and remain predictable during gentle turns. I also examine mounting holes and connector placement, because awkward layouts often cause loose cables. Some advanced features sound useful but remain poorly documented. That is a warning. I once valued maximum processing power too highly; stable firmware made a bigger difference. Review community reports, technical manuals, and update history before choosing. Calibration should be simple, repeatable, and clearly explained.
Choosing a flight controller depends on the aircraft’s weight, sensors, and mission. A basic stabilization controller suits small camera drones and beginners. It keeps attitude control simple, with fewer settings to confuse new pilots. A GPS-assisted controller works better for outdoor filming. Position hold becomes steadier when satellite signals are clear. However, buildings and trees can still reduce accuracy.
A controller with integrated navigation sensors fits mapping drones. It can combine GPS, compass, barometer, and inertial data. This design supports repeatable routes and controlled returns. A long-range controller serves aircraft that need reliable telemetry over wider areas. Its value depends on antenna placement, local rules, and careful signal testing. More range does not automatically mean better safety.
For heavy-lift platforms, a controller with redundant sensors is the practical choice. It can compare measurements and detect unusual readings. This helps when vibration affects the gyroscope. A flexible, open-configuration controller suits experienced builders who adjust filters and control rates manually. It offers useful control, but poor tuning can create dangerous oscillation. Bench testing, propeller balancing, and gradual flight checks remain essential. My preference is conservative tuning, although it can make a drone feel less responsive. That trade-off still deserves review. Firmware quality, documented failsafes, and clear setup procedures should influence every purchase.
Compatibility starts with the frame and electronics, not a product label. Check the controller’s mounting pattern, board dimensions, input voltage, and available connectors. Then verify support for your receiver, GPS, electronic speed controllers, and chosen firmware. A connector may fit while its pin order does not. Compare the wiring diagrams carefully.
Installation should leave room for airflow and maintenance. Secure the board firmly, but avoid overtightening its soft mounting grommets. Keep power wires away from sensitive signal leads where practical. Before connecting a battery, inspect polarity and continuity with a meter. In configuration software, select the correct sensor orientation, receiver protocol, motor layout, and output settings. Calibrate sensors on a level surface, then test controls without propellers. A compatibility chart helps, but it cannot confirm every wiring revision. That part deserves a second look.
Tips: Photograph each connection before installation. Change one setting at a time, and record what you changed. If sensor readings drift or motors respond unevenly, stop and recheck the setup.
| Controller Type | Processor and Firmware Fit | Useful I/O and Features | Airframe Compatibility | Installation and Configuration Considerations | Best Suited For |
|---|---|---|---|---|---|
| Full-size H7 autopilot board | Uses an STM32H7-family processor; some members of this family operate at up to 480 MHz. ArduPilot or PX4 support depends on the exact board and its firmware target. | Often provides multiple UARTs, sensor connections, and sometimes CAN; motor-output count and output protocols vary by board. | Well suited to larger multirotor frames when the controller supports the required motor layout and the frame has room for the board and wiring. | Confirm the board’s mounting holes, power-input range, and supported firmware target. Set the frame type, motor order, output functions, and failsafe behavior before flight. | GPS-assisted builds, larger aircraft, and projects needing extensive telemetry or peripheral connections. |
| Compact H7 multirotor board | Uses an H7-family processor, but compact boards differ in available memory, sensor layout, and firmware support. Check the exact target rather than relying on processor family alone. | Usually offers a capable processor with fewer connectors or less expansion space than a full-size autopilot board. | Can fit Tarot-style frames if the mounting pattern, board dimensions, and stack height match the frame’s electronics bay. | Measure the available plate area and check connector clearance. Use vibration isolation when appropriate, and keep the compass away from high-current wiring. | Builds needing strong processing capability in a restricted installation space. |
| F7 multirotor flight controller | Uses an STM32F7-family processor; the family’s maximum clock rate is up to 216 MHz. Betaflight and iNav are common on supported targets; other firmware requires explicit board support. | Commonly provides several UARTs and multiple motor outputs, but the count, signal type, and peripheral support are board-specific. | Suitable for many quad, hexacopter, and other multirotor builds when the board’s outputs and firmware support the selected configuration. | Match the motor layout to the firmware configuration. Verify UART assignments for GPS, receiver, telemetry, and digital video systems before wiring. | General-purpose multirotors needing a balance of processing capability, size, and peripheral support. |
| F4 multirotor flight controller | Uses an STM32F4-family processor; clock speed and memory depend on the specific chip. Many boards support established Betaflight or iNav targets, but support varies by model. | Often has fewer spare resources or peripheral connections than newer H7 designs; check the board documentation for available UARTs and outputs. | Can control a Tarot-style multirotor if its output count, firmware target, and mounting arrangement meet the build requirements. | Confirm that the required firmware version still supports the exact target. Plan serial-port use carefully, especially when adding GPS, telemetry, or other peripherals. | Cost-conscious or simpler builds that do not require many peripherals or advanced processing features. |
| Flight-controller and ESC all-in-one board | Processor and firmware depend on the integrated board; common designs use F4, F7, or H7 processors. Confirm support for the exact board target and ESC protocol. | Combines the flight controller with electronic speed controllers, reducing separate power and signal wiring. Current rating and motor-output count are model-specific. | Useful where the airframe has limited electronics space, provided the integrated ESCs are rated for the chosen motors, propellers, battery, and cooling conditions. | Check continuous-current ratings, battery voltage limits, cooling airflow, and connector polarity. Keep high-current wiring secure and follow the board’s power-supply instructions. | Compact builds prioritizing fewer components and simpler wiring over modular replacement. |
Compatibility note: These are controller categories, not specific products. A Tarot airframe does not determine which firmware or controller will work: verify the exact board’s supported firmware target, mounting-hole pattern, motor-output requirements, power system, and sensor connections before purchase or installation. Board specifications vary even within the same processor family.
Choosing a flight controller starts with the aircraft, not the feature list.
Match its outputs to the motor layout, and confirm support for your intended firmware. Check available ports for GPS, telemetry, and payload sensors. Fit matters more.
Weight and vibration can change performance. A compact frame may leave little room for clean wiring or cooling. Check the controller’s mounting pattern, voltage range, and power capacity against your battery and electronic speed controllers.
Then inspect the failsafe options, sensor redundancy, and flight-log quality. Logs help reveal drift, vibration, or power issues after a test flight.
I would not choose a board based on processor speed alone; reliable sensor data and practical setup support often matter more.
The FAA’s 2024 Aerospace Forecast estimates the U.S. commercial small-drone fleet could grow from about 412,000 aircraft in 2023 to 858,000 by 2028. That forecast describes fleet growth, not controller demand, but it highlights the need for dependable integration.
Before buying, compare the controller’s documented interfaces with your exact parts list. Bench-test sensor readings and motor outputs without propellers, then perform cautious hover checks in a suitable open area.
One detail is easy to miss: a controller may support a feature in theory, while your wiring or firmware configuration does not. Verify both.